Saad Mahboob
A 3D model of a Unitree H1 humanoid robot stands on the floor line in front of my name. It waves, and turns to follow your cursor.
Senior Robotics EngineerProduct owner, fleet management
I build robot products, from the business case to the customer’s warehouse floor. Three shipped, and now I own fleet management. Humanoids are next.
Open to product roles at humanoid and robotics companies. Get in touch
Stuttgart, Germany
About me
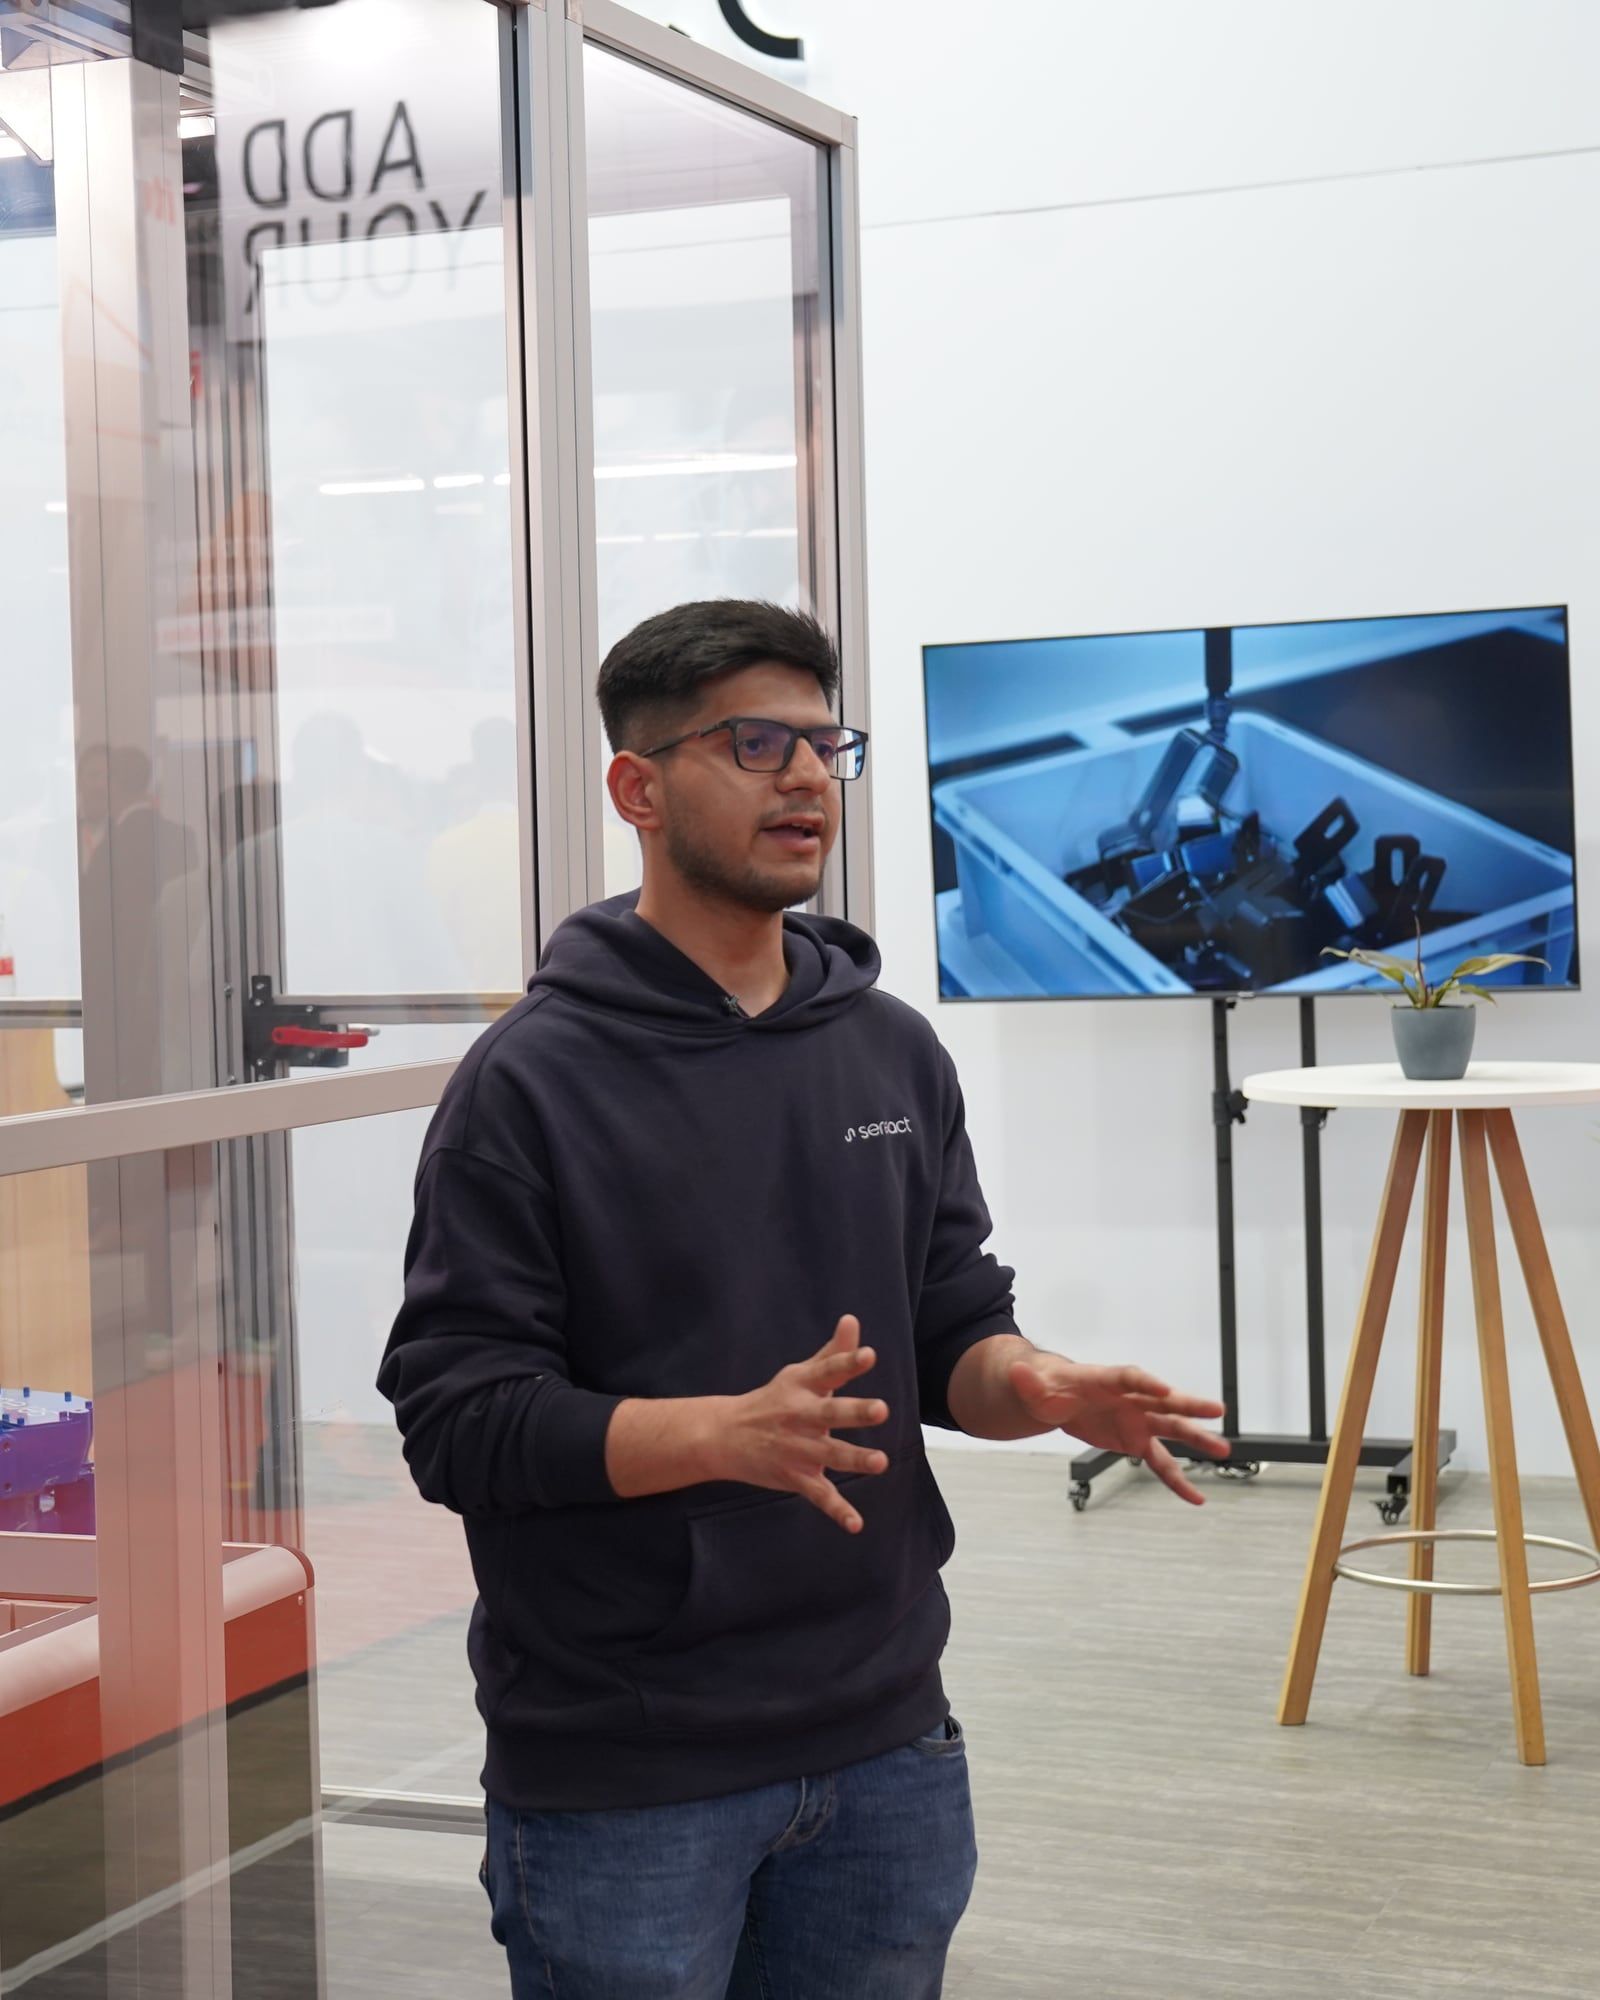
I’m a robotics engineer at Sereact in Stuttgart, where I own fleet management: the tools that deploy, run and fix our robots across customer sites. Three products I took from business case to customer are in daily use.
I deploy the robots too, and stay until they pass acceptance. Next is humanoids. On a Unitree H1 I built the teleoperation, led the data collection and ran NVIDIA GR00T on board.
Product is the part I want full-time: find the problem on the floor, make the business case, ship it, and own the results.
Shipped and signed off
Products with customers, and numbers from live sites and acceptance tests.
3
Products, idea to customer
A fashion picking line, chilled picking and a plug-and-play signal controller.
2
Sites running returns automation
For Zalando and CEVA, with bag-opening control software I built with a colleague.
+60%
Warehouse throughput at Rohlik
Delivered inside a tight warehouse layout.
9+
Site acceptance tests passed
Run and signed off on site, with more on the way.
3 days
Two stations live
Live on the software side in three days, with acceptance passed in five.
In other people’s words, and mine
Saad is the final end boss.
- picks per hour
- 540
- average reaction time
- 4 min
- average remote fix
- 21 min
Figures from the same post.
“We see the pain points and we just say we’re going to solve it, whatever it takes.”
Humanoids are next
Where humanoids pay off first
I scoped six warehouse and retail use cases where a humanoid earns its place. Restocking a shelf is one of them.
Pick, carry, place
Picking and placing are what I’ve shipped: 6-DOF grasp generation and placement logic in a depalletizing stack that runs at customer sites.
From demo to daily use
On a Unitree H1 I built the teleoperation and led the data collection for a live demo. Getting robots into daily use is the product work I do now.
Animated in your browser from the H1’s joint model. An illustration, not footage.
Case studies
Four stories, products first, told the way I’d tell them in an interview: the problem, what I did and what changed.
Three products
- 96%scan rate in the chilled picking cell
- 2cities where the signal controller runs with customers
Three robot products, from idea to customer
I took three products from first idea to customers: hardware, software, testing, site acceptance and, for one of them, the sale itself.
Fleet management
- Weeklyrelease train, from merge to customer fleet
- 1 clickto send a tested release to customers
The product I own now: deploying, running and fixing a robot fleet
Every robot that ships needs deploying, testing, supporting and fixing. I own fleet management at Sereact: the tools that make that faster, and the site fixes we turn into platform features so every customer gets them.
Rohlik Group
- 98%of daily situations covered by my Operator’s Guide
- 51 to 100stations in the public rollout plan
Six months on site, scaling AI picking for e-grocery
I led Sereact’s robot picking deployment at Rohlik Group from the warehouse floor: on site for six months, later as project manager, and the person called when something broke.
Humanoids
- Livedemo for a funding round
- 6warehouse and retail use cases scoped
Getting a Unitree H1 to unbox shoes
I owned Sereact’s humanoid demo for a funding round: from building the teleoperation and gathering the training data to a live demo on a Unitree H1, running NVIDIA GR00T on board.
Where I’ve worked
2025 – now
Senior Robotics Engineer, Sereact
Stuttgart
AI picking robots for warehouses: three products shipped, fleet management as the product I own now, deployments and humanoids.
2023 – 2025
Computer Vision Engineer, TVConal
Singapore, remote
Real-time AI tracking for live cricket broadcasts: 10x faster inference with TensorRT, multi-camera ball trajectories for decision reviews, and a 30 fps player-tracking interface.
2021 – 2022
Deep Learning & Swarm Intelligence Intern, Public-sector research lab
Graph neural networks that predict where every agent in a swarm moves next, PSO and ACO swarming in Gazebo and ROS, and coordinated PX4 drone swarm flights.
Education
- MSc RoboticsMiddlesex University London, 2023 – 2024
- BSc Electrical & Electronics EngineeringFAST-NUCES, Islamabad, 2019 – 2023Academic award at graduation
What I work with
- Humanoids & manipulation
- Unitree H1 and G1, twist2 teleoperation, Imitation learning data, NVIDIA GR00T, 6-DOF grasp generation, Placement planning, Gripper design
- Robotics
- ROS 2, Behaviour trees, Motion planning, ORB-SLAM3, UR10, Yaskawa, ABB IRB 120, Jetson, ESP32
- ML & vision
- PyTorch, TensorRT, OpenCV, Graph neural networks, Vision-language models
- Software & ops
- Python, C++, Docker, FastAPI, RabbitMQ, Release management
Let’s build robots that ship.
I’m looking for robotics product roles, from product manager to technical product owner or pilot lead, at humanoid and robotics companies. On-site or hybrid in Germany. I hold an EU Blue Card.